Research
The work at Drexel’s Community-Centered Advanced Mobility (CAM) Lab connects travel behavior, infrastructure systems, and emerging vehicle technologies to address fundamental questions about how transportation technologies and services can better serve people and communities. We draw on theories and methods from behavioral modeling, optimization, control, artificial intelligence, and experimental validation to develop mobility solutions that are behaviorally realistic, operationally effective, and physically executable. Applications include connected and automated transportation, public transit, and shared mobility. Ultimately, we aim to translate these theoretical and methodological advances into safe, efficient, and sustainable transportation solutions in collaboration with transportation agencies, industry partners, and communities.
Travel Behavior
A transportation solution designed without considering the people it serves is unlikely to succeed. Some of the questions we ask in this area are: What shapes individual travel choices? How can we build travel choice models that are accurate, fair across population groups, and scalable to millions of travelers? How can frontier AI models help us develop these models and discover new behavioral insights? How can we integrate individual choices into regional travel demand simulations to assess who benefits and who bears the burdens when transportation systems change? To answer these questions, we develop behavioral models and agent-based simulations to understand how people respond to—and are affected by—transportation technologies and services.
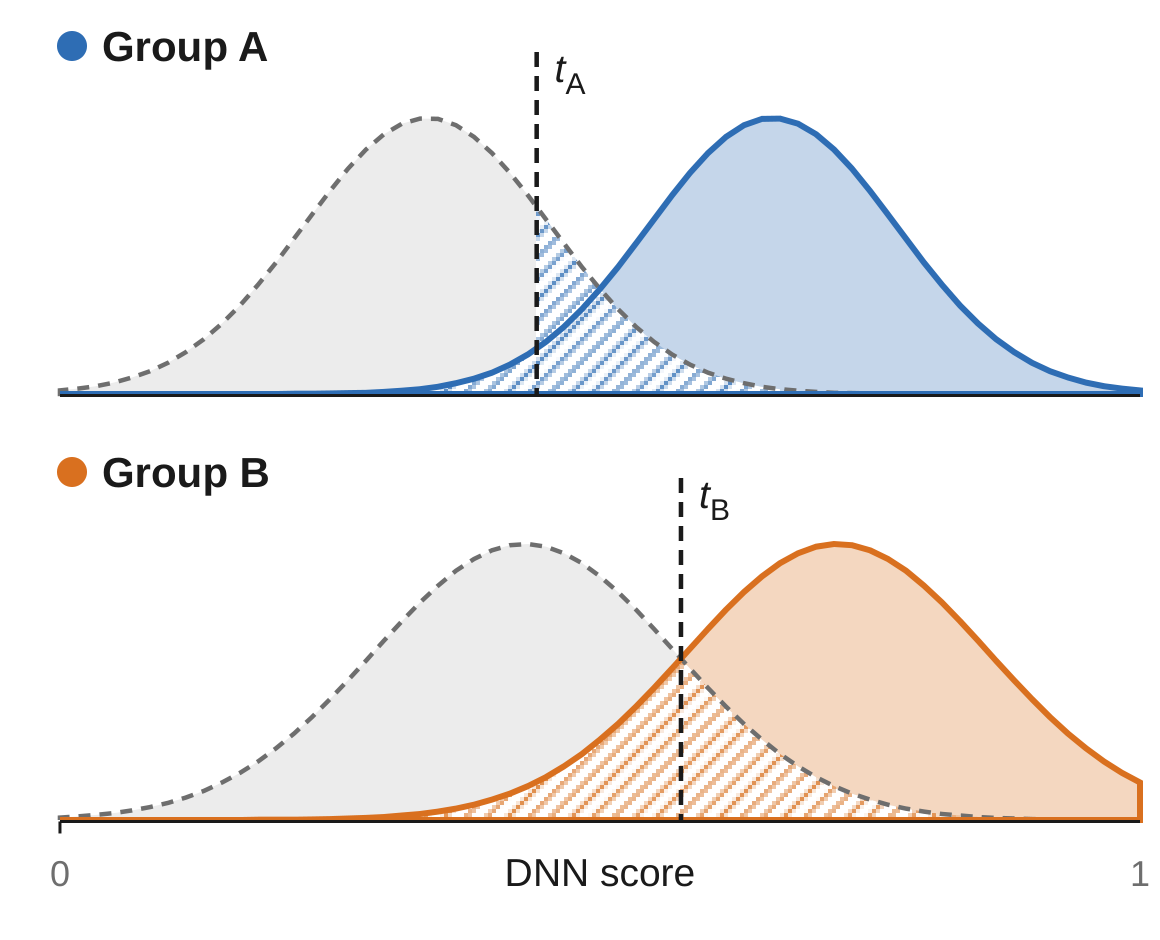
DNN for Choice Modeling
Developing Deep Neural Networks (DNNs) for accurate, fair, and interpretable travel choice predictions across population groups.
Project details
LLM as Choice Modeler
Using Large Language Models (LLMs) to develop and interpret travel choice models, combining AI capabilities with human behavioral expertise.
Project details
Distributional Impact Evaluation
Using large-scale agent-based travel simulation to evaluate how transportation technologies and services distribute benefits and burdens across travelers.
Project detailsInfrastructure Systems
Changing travel demand, emerging transportation technologies, new mobility services, and transportation infrastructure failures create challenges for infrastructure system planning, design, operations, and maintenance that existing models were not designed to address. For example, modular vehicles allow capacity to change as demand fluctuates, shared mobility services connect network design with travelers’ choices, and infrastructure failures can reshape travel patterns across a region. These changes call for rethinking both how transportation systems are modeled and how decisions are made. We develop optimization models, analytical and data-driven methods, and computational algorithms to understand these challenges and support effective transportation decisions.
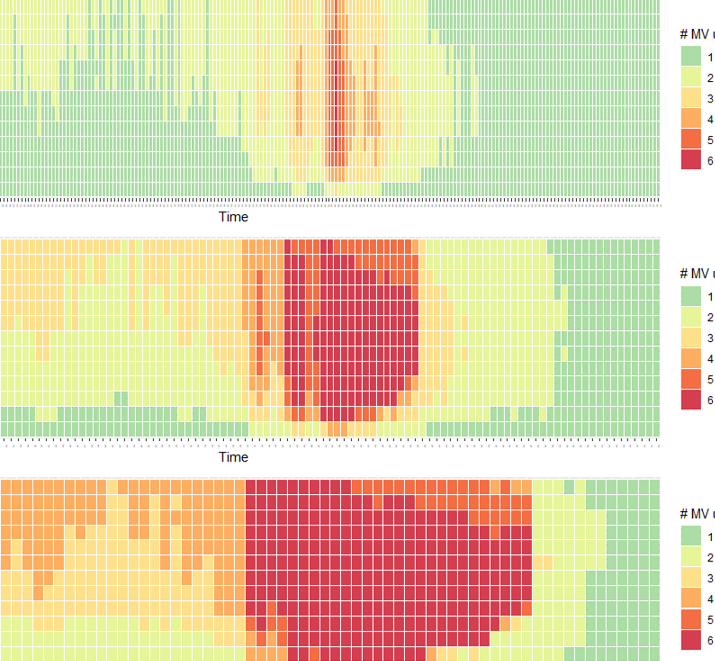
Modular Automated Transportation
Developing optimization models and algorithms for transportation systems whose vehicles can assemble and disassemble to match changing demand.
Project details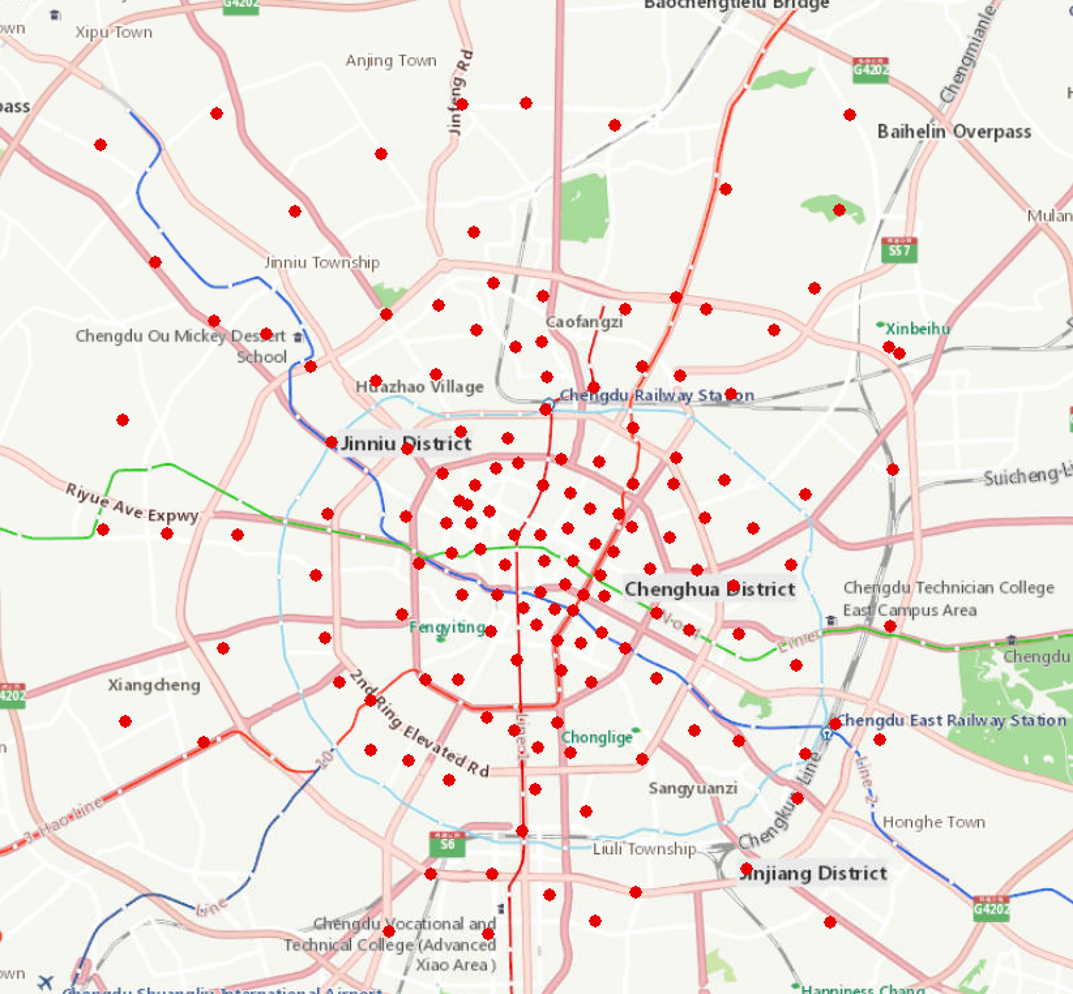
Transportation Network Design
Developing optimization models and algorithms for transportation network design that account for emerging transportation technologies and services.
Project details
Decision-Embedded Learning
Developing decision-embedded learning methods that integrate transportation optimization into model training to improve decision quality directly.
Project details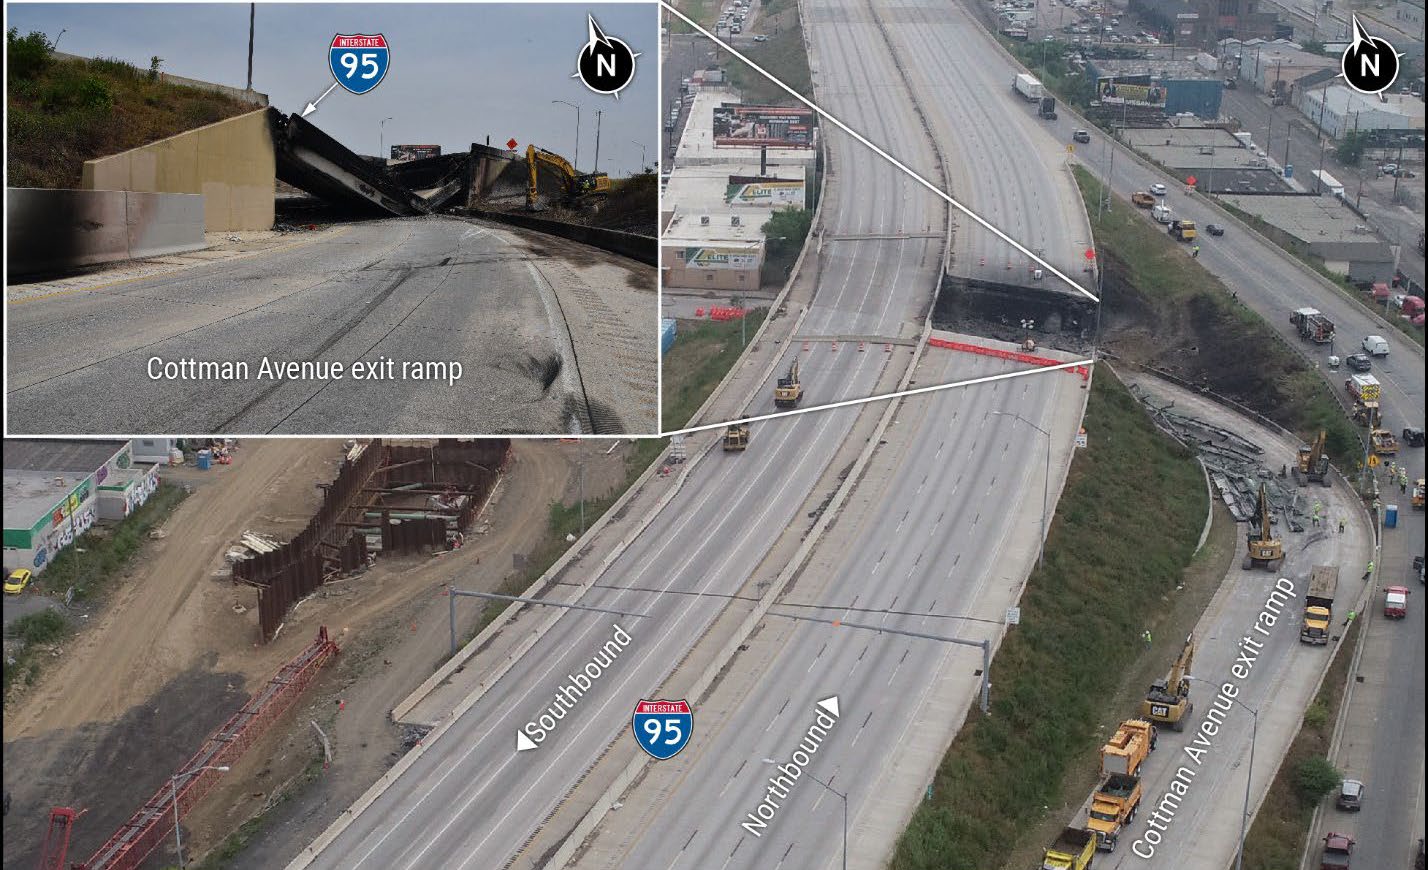
Transportation Resilience
Developing interactive data platforms to collect, curate, and visualize traffic data for understanding transportation disruptions and supporting response and recovery.
Project detailsVehicle Technology
Transportation system designs can deliver their intended benefits only when vehicles can make them work on the road. This is especially the case for Connected and Automated Vehicles (CAVs); they must locate themselves, anticipate how surrounding road users will move, plan safe maneuvers, and execute those movements reliably. Dense urban environments and mixed traffic make these tasks challenging as observations can be incomplete, human behavior can be ambiguous, and vehicle dynamics can change. We develop localization, prediction, planning, and control methods for CAVs, and evaluate their performance through simulation, robotic vehicles, and full-scale vehicle experiments.

Motion Planning
Developing vehicle motion planning methods that account for interactions among road users, safety requirements, and uncertain human behavior.
Project details
Trajectory Control
Developing adaptive control methods to execute planned vehicle trajectories and evaluating performance through physical vehicle experiments.
Project details
Vehicle Localization
Developing localization methods that use semantic points of interest to improve automated vehicles’ positioning in urban environments.
Project details